Product 02 Robotic Surgical Trainer
Train on a robot.
Not on a simulator.
Real robot. Real instrument. Real training.
The Robotic Surgical Trainer provides hands-on training on a physical robotic system, allowing trainees to operate a real robotic arm through teleoperation and perform surgical tasks with a real instrument on a physical training platform.
The full recording
- 01 Top left: the operator's hand controller
- 02 Centre: the robot and the entry port
- 03 Top right: the endoscope view of the task
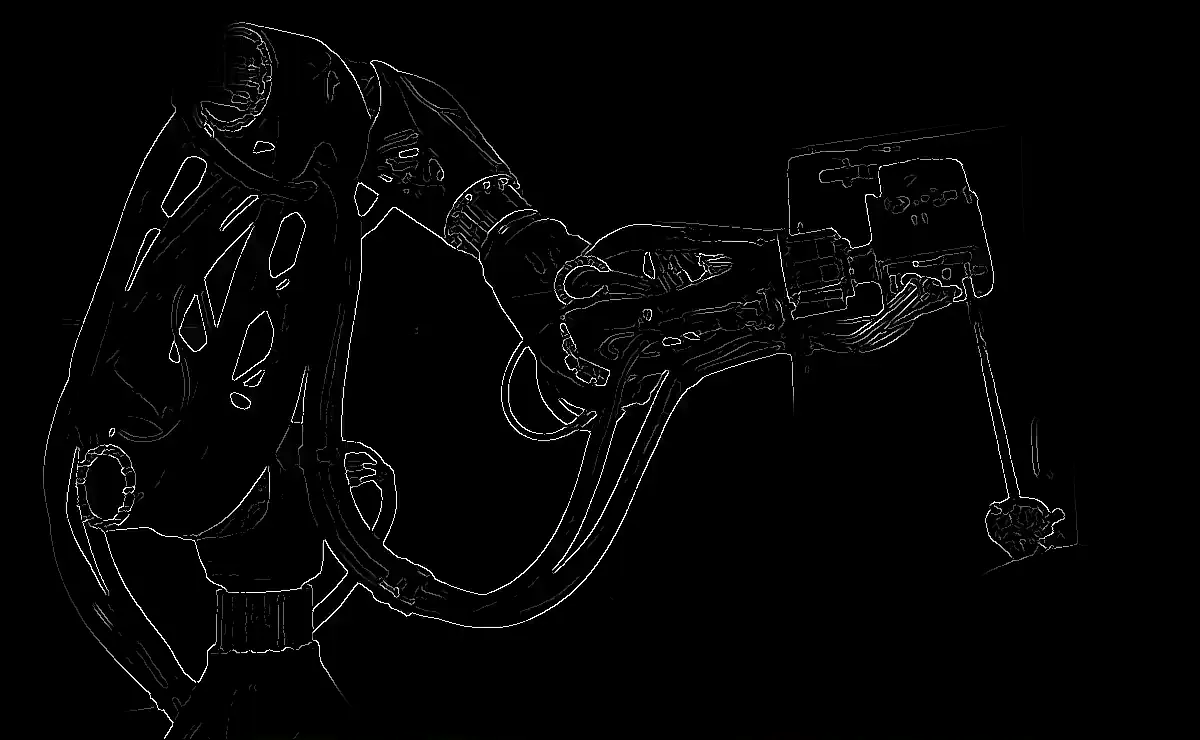
The drawing
is the machine.
This drawing was traced from the footage, frame for frame. Drag across it to compare the two, and pick a joint to find it on the arm.
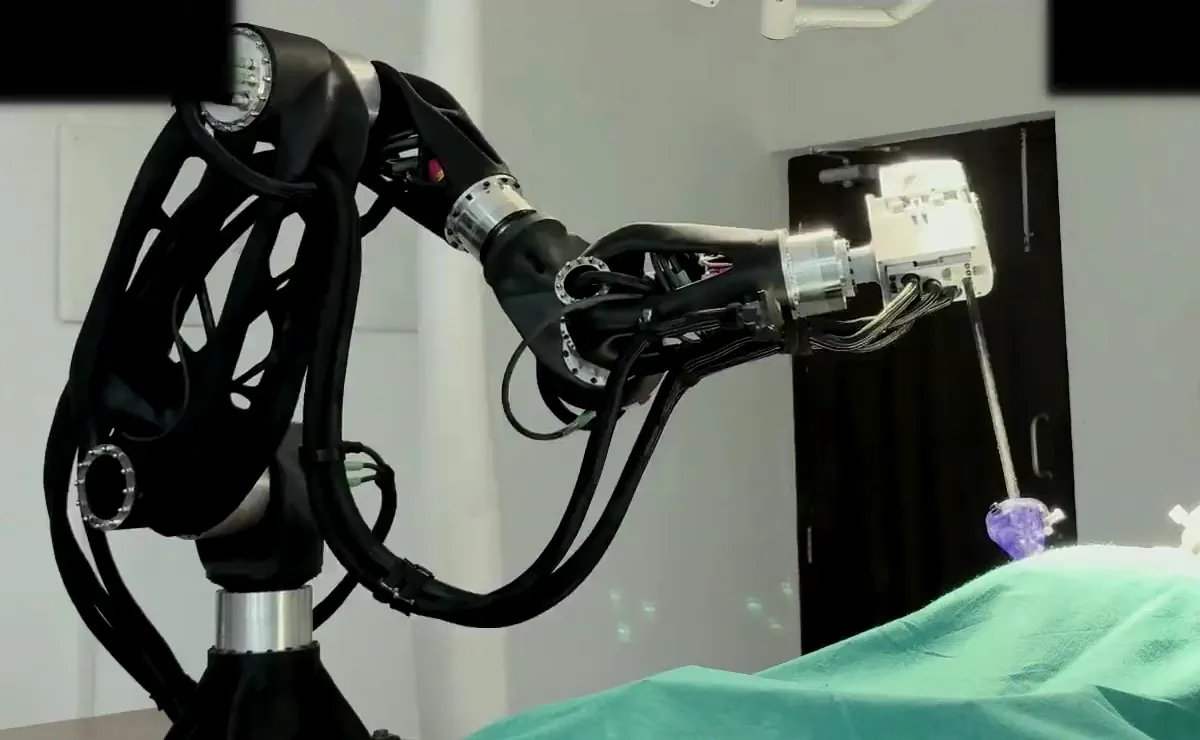
How it works: hand, robot, view.
Three views from a single recording of the Robotic Surgical Trainer. They run on the same clock, so what the hand does on the left is what the instrument does on the right.
- 01
Hand on the controller
The operator guides a hand controller at a desk.
- 02
Robot moves the instrument
The arm carries a real instrument through a real port.
- 03
What the camera sees
The task, viewed through the endoscope.
The complete
setup.
Everything needed for hands-on robotic training, in one system: an operator console with hand controls and a surgical view, paired with a robotic arm and physical training table.
 Concept visualisation
- 01Realistic motion and physics
- 02Real instruments and controls
- 03Costs similar to a simulated platform
What it is.
- A physical robot
- Train on a real robotic arm, with physical movement and instrument control, not a virtual representation.
- Teleoperation
- Operate the robot remotely through intuitive hand controls, mirroring the fundamental interaction of robotic surgery.
- Glasses-free 3D console
- A stereoscopic surgical view with natural depth perception, without the need for 3D glasses.
- Real instruments. Real port.
- A laparoscopic instrument passes through a physical access port and interacts with a surgical training phantom.
- The endoscopic view
- See the procedure through the instrument camera, replicating the visual perspective of minimally invasive surgery.
Build the future
with us.
Hospitals, training centres, researchers and engineers: if you want to work with real robots, write to us.